|
Daniel Kim I'm a third-year undergraduate student at Rice University (Class of 2028) advised by Ashok Veeraraghavan and Guha Balakrishnan. I'm also a robotics researcher at CMU's AirLab, advised by Sebastian Scherer and Wenshan Wang working on learned navigation policies for drones. My interests include computer vision, machine learning, and robotics. |
|
News
|
Publications |
|
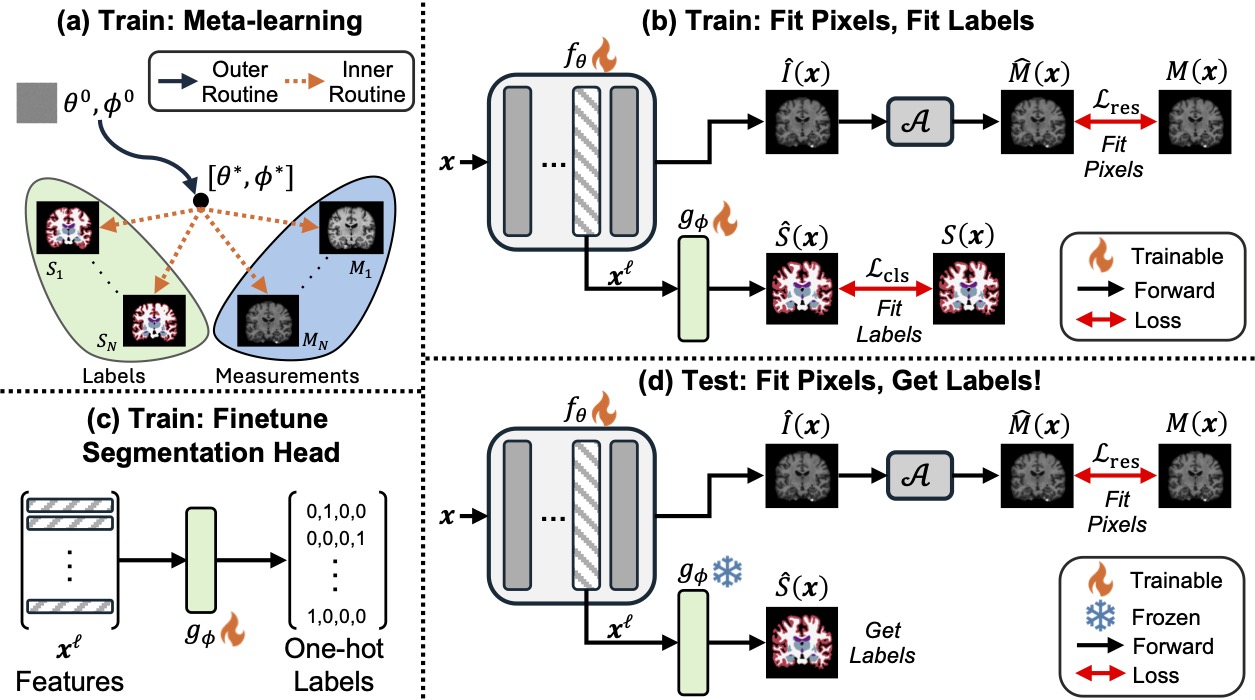
FPGL: A Meta-Learned Implicit Neural Representation Framework for Medical Image Segmentation
Kushal Vyas, Daniel Kim, Tucker Netherton, Ashok Veeraraghavan, Guha Balakrishnan Medical Image Analysis (MedIA), 2026 paper / doi / bibtex @article{vyas2026fpgl,
title = {FPGL: A Meta-Learned Implicit Neural Representation Framework for Medical Image Segmentation},
author = {Vyas, Kushal and Kim, Daniel and Netherton, Tucker and Veeraraghavan, Ashok and Balakrishnan, Guha},
journal = {Medical Image Analysis},
volume = {115},
pages = {104316},
year = {2026},
doi = {10.1016/j.media.2026.104316}
}
Meta-learns a shared INR initialization by jointly fitting scans and segmentation maps, so novel subjects can be segmented simply by fine-tuning on their raw test-time observations. |
|
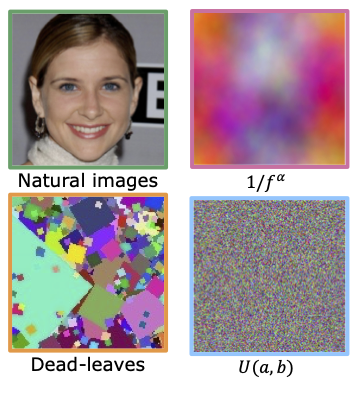
The Surprising Effectiveness of Noise Pretraining for Implicit Neural Representations
Kushal Vyas, Alper Kayabasi, Daniel Kim, Vishwanath Saragadam, Ashok Veeraraghavan, Guha Balakrishnan CVPR, 2026 project page / arXiv / pdf / bibtex @inproceedings{vyas2026surprising,
title = {The Surprising Effectiveness of Noise Pretraining for Implicit Neural Representations},
author = {Vyas, Kushal and Kayabasi, Alper and Kim, Daniel and Saragadam, Vishwanath and Veeraraghavan, Ashok and Balakrishnan, Guha},
booktitle = {Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
year = {2026}
}
Pretraining INRs with structured noise yields dramatic signal-fitting improvements. Noise with 1/|fα| spectral structure matches the best data-driven initialization methods. |
|
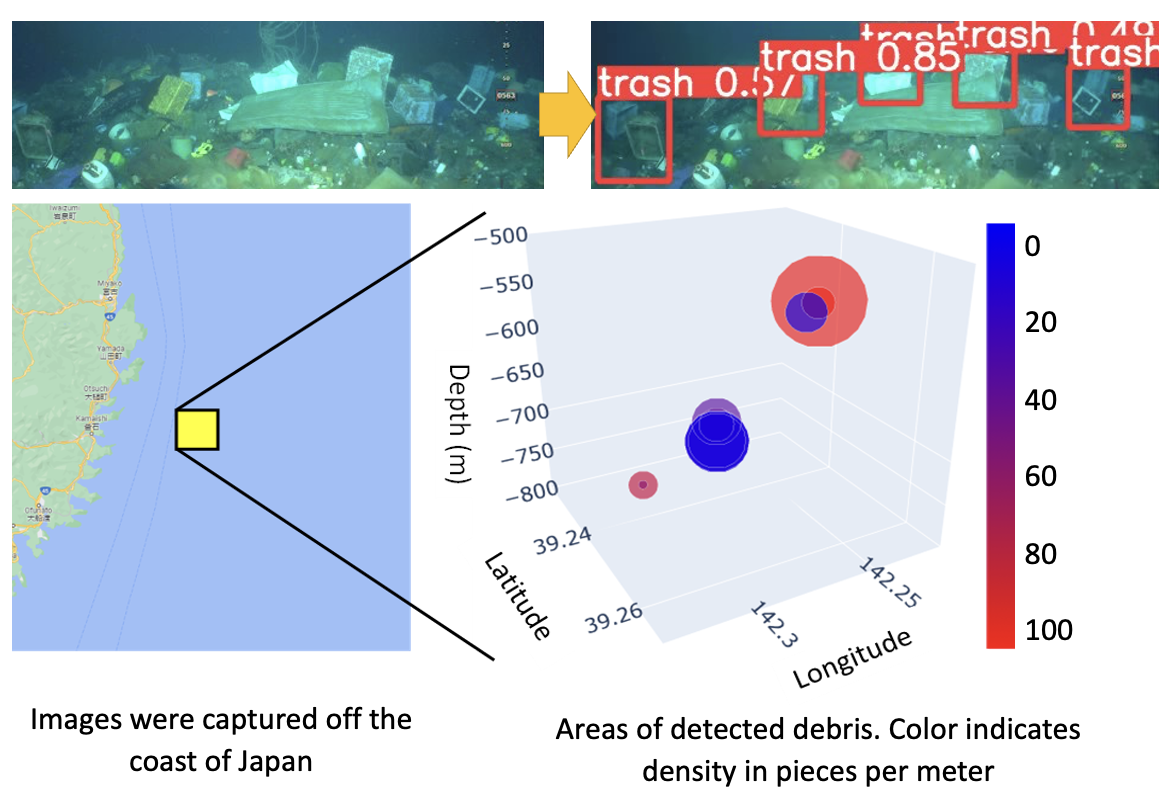
Engineered Underwater Vehicle for Ocean Litter Mapping
Daniel Kim New Mexico Journal of Science, 2024 project page / video / code / bibtex @article{kim2024oceanai,
title = {Engineered Underwater Vehicle for Ocean Litter Mapping},
author = {Kim, D.},
journal = {New Mexico Journal of Science},
year = {2024}
}
An autonomous underwater vehicle using YOLOv5 and SLAM to map subsurface debris, identifying 174,000+ pieces of litter. |
|
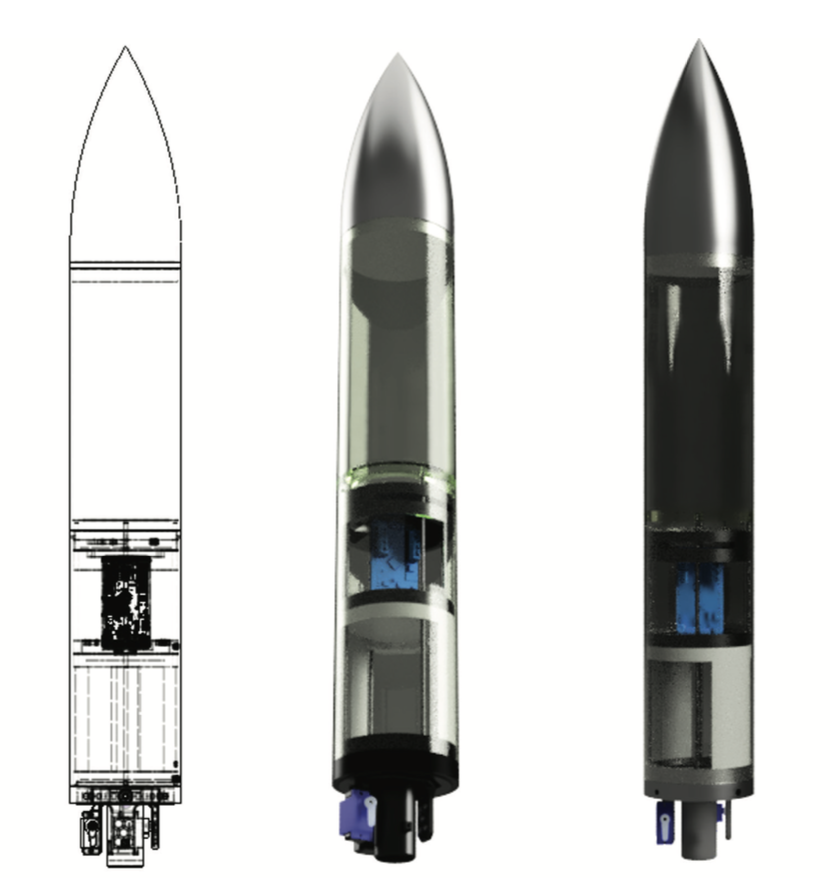
Developing a Control Algorithm and Simulation for Thrust Vector Controlled Rockets
Daniel Kim, A. Iturregui New Mexico Journal of Science, 2022 project page / video / bibtex @article{kim2022tvc,
title = {Developing a Control Algorithm and Simulation for Thrust Vector Controlled Rockets},
author = {Kim, D. and Iturregui, A.},
journal = {New Mexico Journal of Science},
year = {2022}
}
A PID-based control algorithm and 6-DOF flight simulation for model rockets with thrust vector control. |
Projects |
|
3D Gaussian Splatting for Learned Drone Navigation
CMU Robotics Institute Summer Scholars (AirLab), 2026 project page / paper / poster A photorealistic, differentiable drone simulator built from 3D Gaussian Splat reconstructions, used to train monocular RGB navigation policies across diverse scenes. |
|
|
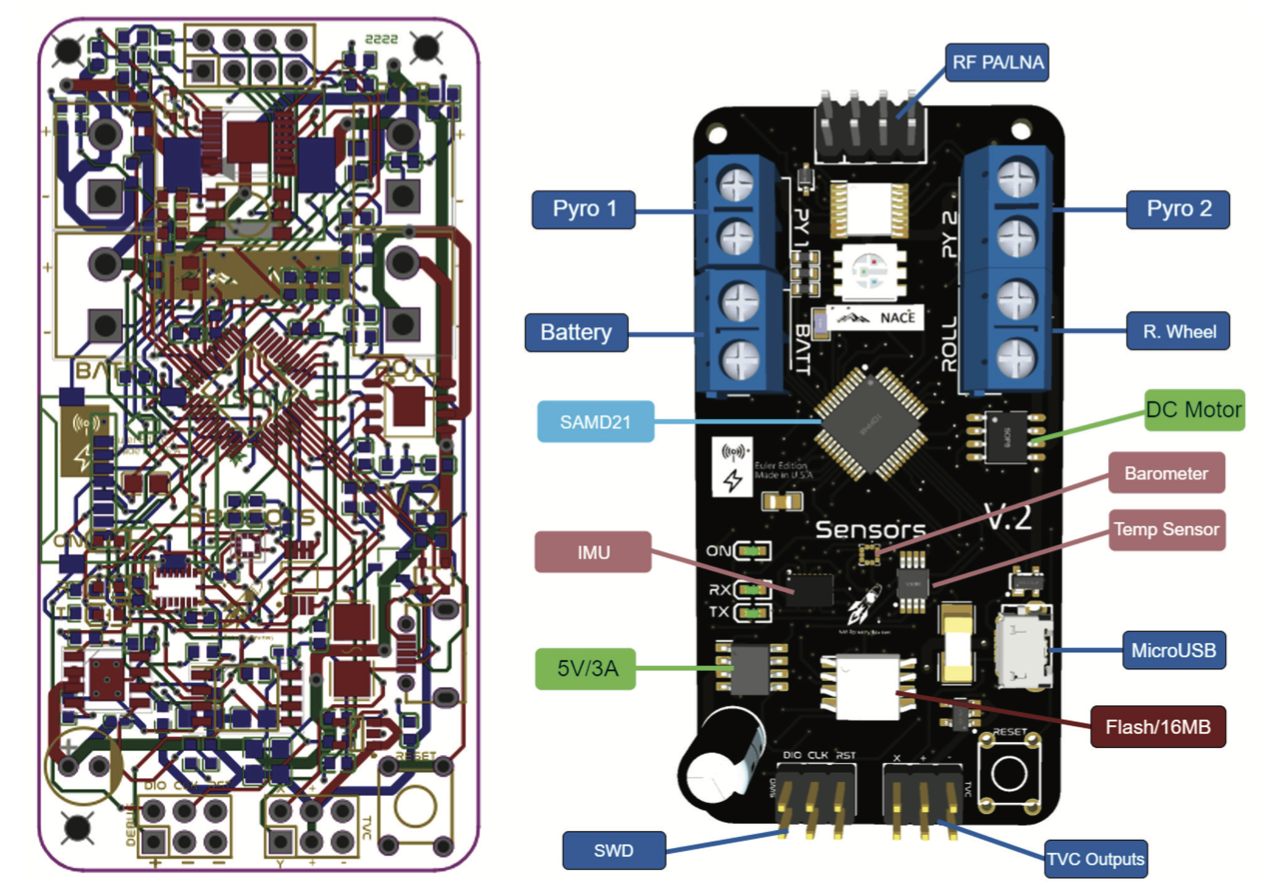
Ember: Rocket Active Control
project page / code A custom Teensy-based flight computer and thrust vector control system that actively stabilizes model rockets during ascent, starting from PID control with Kalman filtering. Ember extends it with a differentiable 6-DOF rocket simulator that trains a neural TVC controller by backpropagating through the physics, then flies the learned policy on the real hardware. |
|
Alpine
project page A modular PyTorch library for rapidly prototyping implicit neural representations, with object-oriented interfaces and visualization tools for scientific computing. |
|
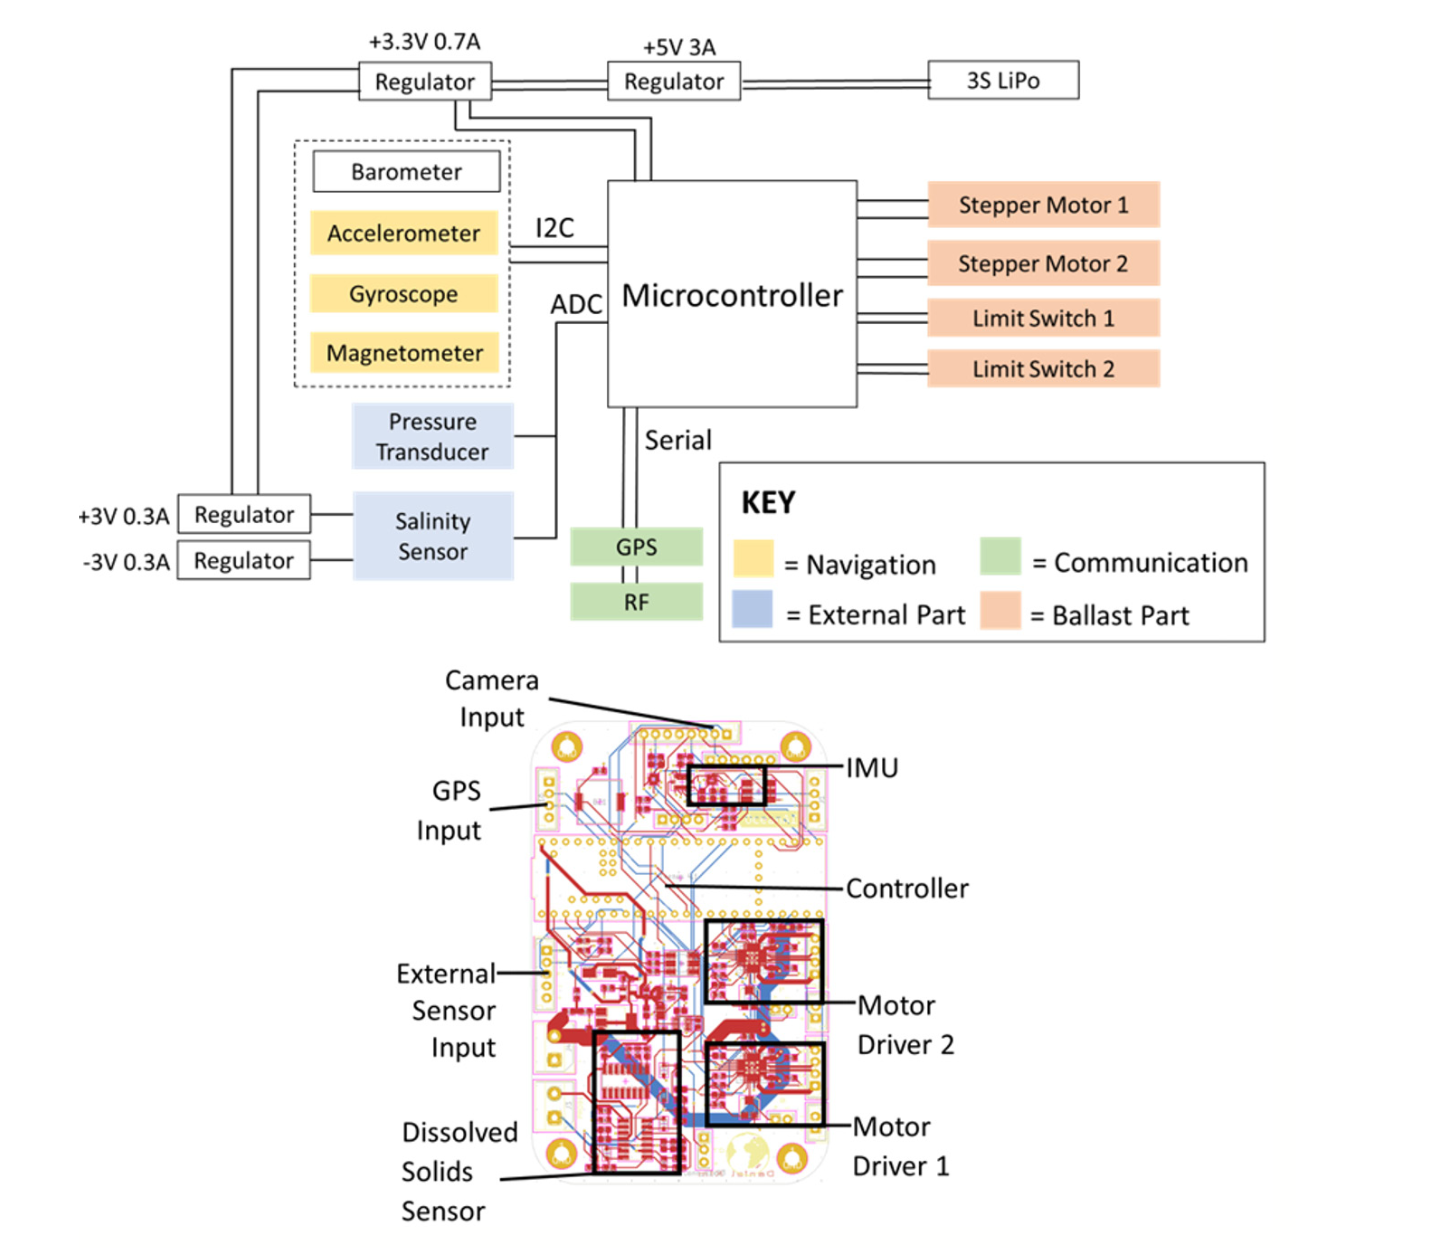
OceanAI
project page / code An autonomous underwater glider with a custom YOLOv5 vision pipeline and SLAM navigation that identified over 174,000 debris objects. |
|
StudyBeats
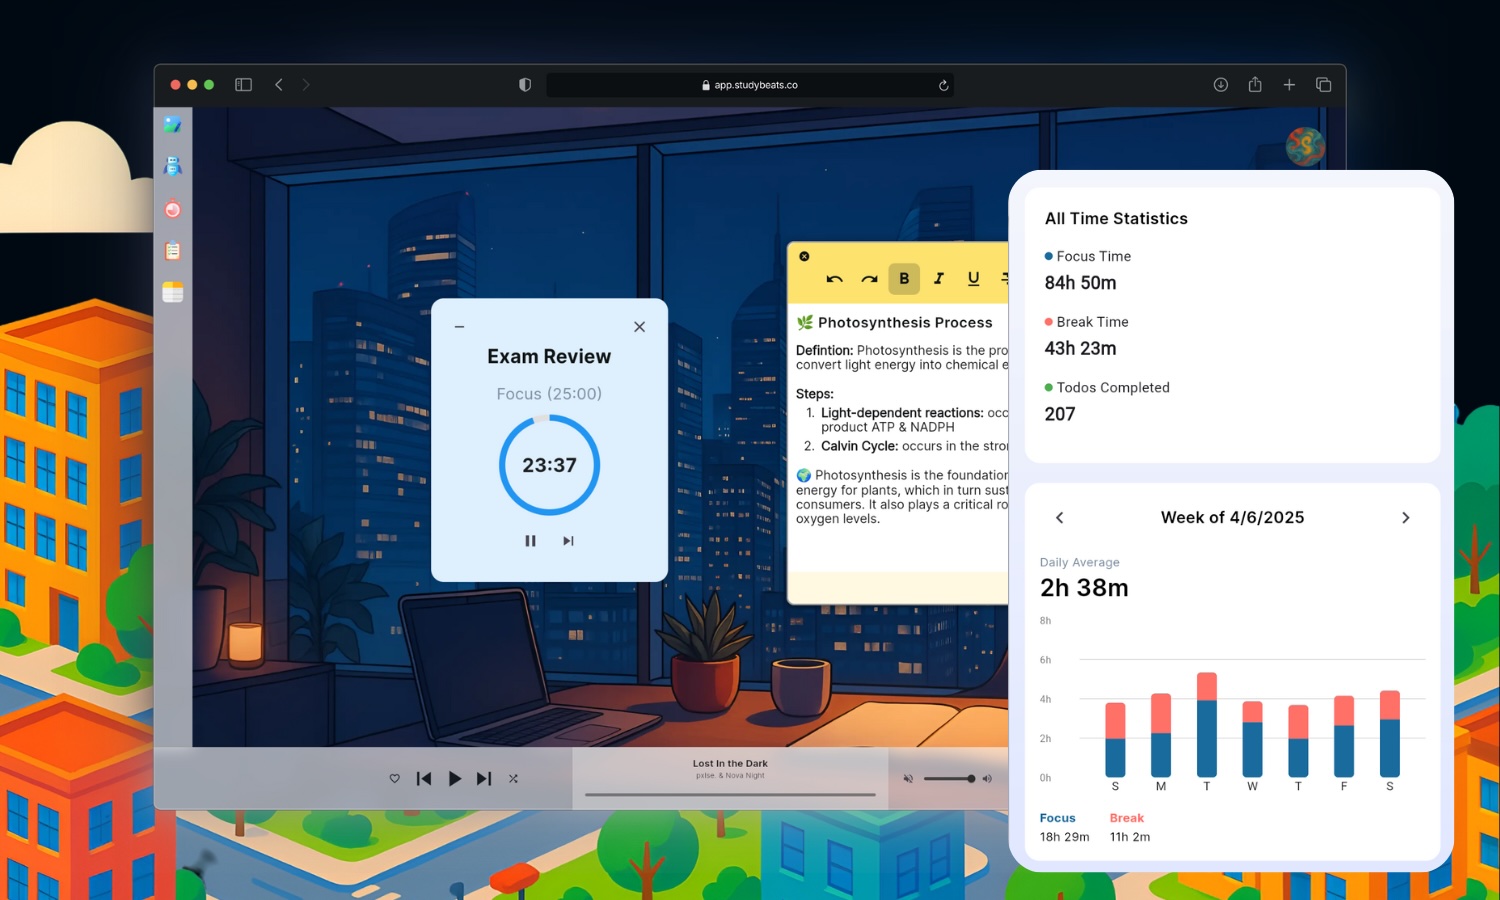
project page A real-time productivity platform with focus tools, task sync, and Lo-Fi streaming, serving 1200+ users. |
|
OrbitSim
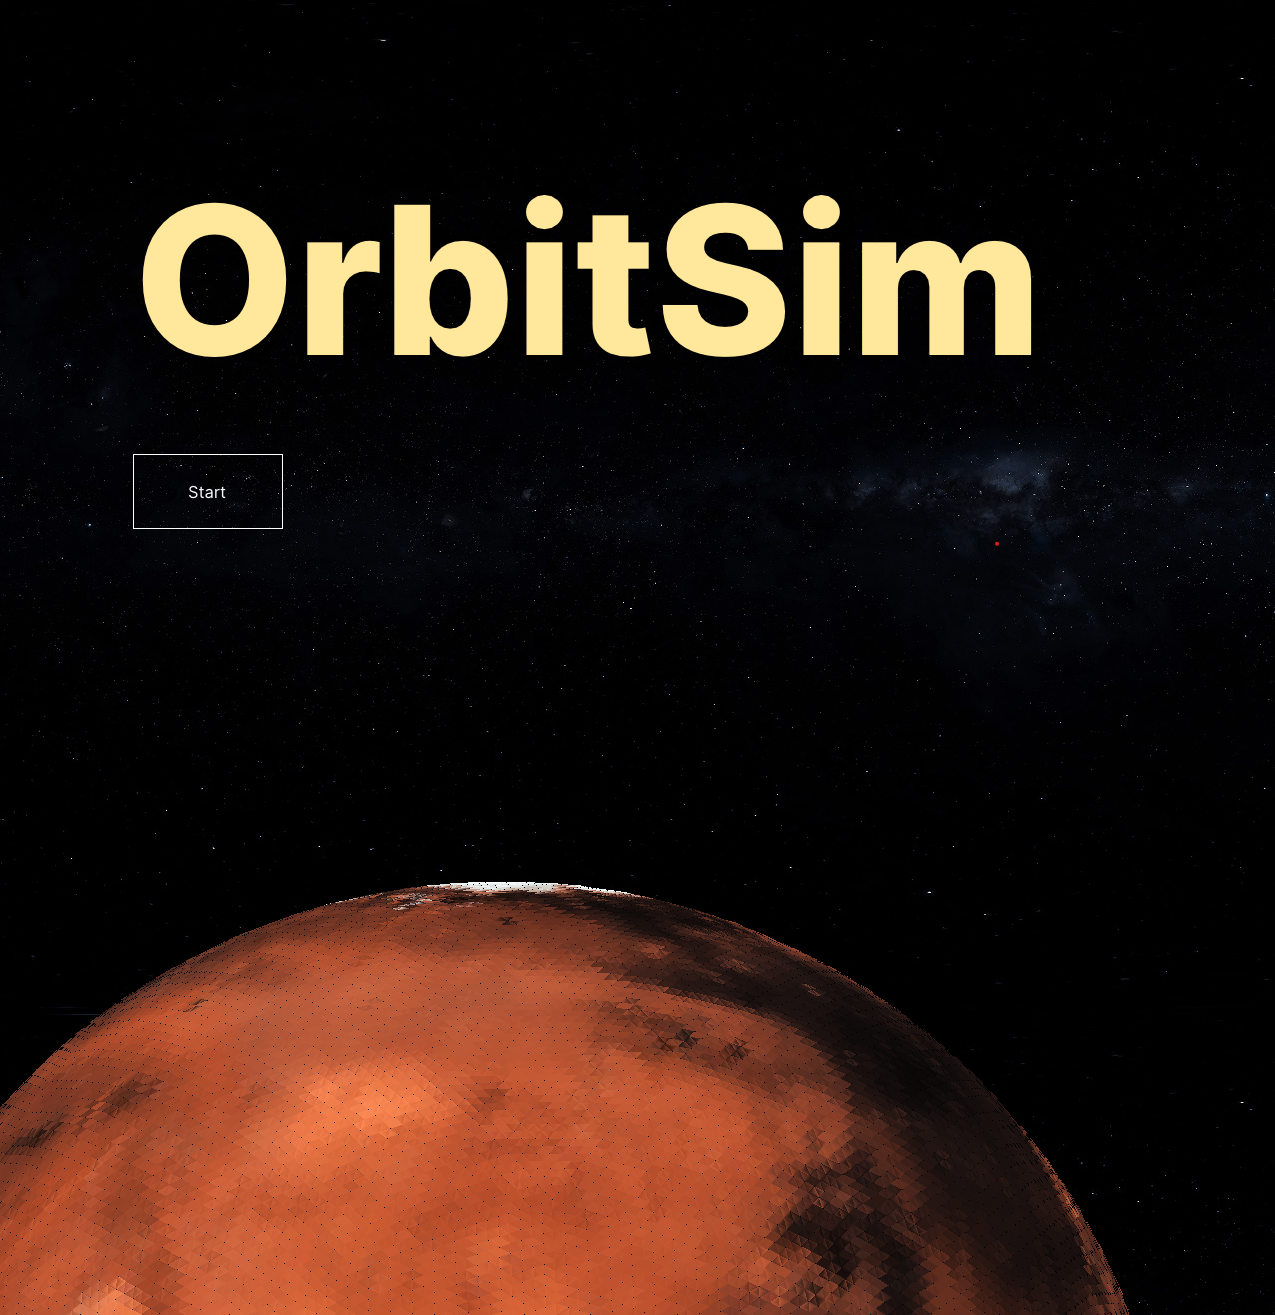
project page An N-body gravity simulator visualizing 8,000+ active satellite trajectories in real time, built on a custom C++ engine with Vulkan rendering. |
|
Website template from Jon Barron. |